
Introduction
Robotics assemblies place far greater demands on fastening reliability than static printed prototypes.
A robotic structure may experience:
- continuous vibration
- repeated motion cycles
- changing load directions
- impact forces
- repeated maintenance
- dynamic torque loading
In these environments, directly threaded plastic holes often fail quickly.
Heat set inserts provide reusable metal threads that improve structural reliability, serviceability, and long-term fastening stability in robotic assemblies.
Reliable fastening becomes especially important because many robotics systems involve moving joints, actuator mounts, sensor brackets, and modular structural components. For actuator mounts, servo brackets, and moving joints, torque resistance is often more important than basic thread retention.
A fastening point that works in a static enclosure may fail rapidly inside a continuously moving robotic system.
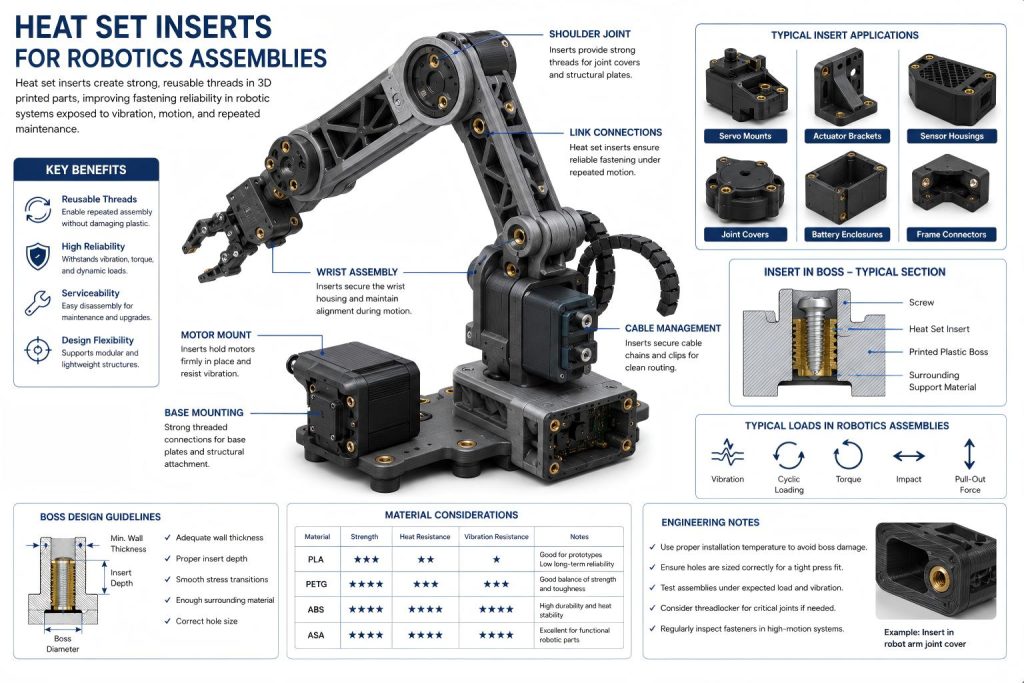
Why Robotics Assemblies Use Heat Set Inserts
Robotic systems are highly dynamic mechanical structures.
Fastening points often experience:
- vibration
- cyclic loading
- repeated acceleration
- directional force changes
- maintenance disassembly
Heat set inserts improve reliability by creating durable threaded interfaces inside printed thermoplastic parts.
Common advantages include:
- reusable threads
- improved torque resistance
- reduced thread wear
- better maintenance capability
- improved structural retention
- reduced loosening risk
- improved assembly repeatability
Reliable fastening is critical in robotics because even small joint movement may affect motion accuracy and structural stability.
Common Robotics Parts That Use Inserts
Heat set inserts are commonly used in:
- servo mounts
- actuator brackets
- robotic arm joints
- sensor housings
- motor mounts
- cable management systems
- battery enclosures
- maintenance panels
- modular frame assemblies
- wheel and suspension brackets
Many robotics projects rely on inserts to allow repeated assembly without damaging printed structures.
Why Fastening Reliability Matters in Robotics
Robotics systems continuously transfer force through the structure.
Poor fastening reliability may cause:
- vibration instability
- joint looseness
- alignment drift
- motion inaccuracy
- structural cracking
- maintenance problems
Fastening systems must resist both static and dynamic loads.
Reliable insert performance improves:
- positional stability
- long-term rigidity
- assembly consistency
- serviceability
- vibration resistance
Dynamic Load Behavior in Robotics
Unlike static printed parts, robotics assemblies experience constantly changing force directions.
These forces create repeated stress cycles around the insert structure.
Common Dynamic Loads
- rotational torque
- vibration
- impact loading
- cyclic pull-out force
- acceleration loads
- directional stress reversal
Dynamic loading gradually weakens poorly designed fastening structures.
When inserts are exposed to repeated pulling or impact loads, pull-out strength becomes a key part of robotic joint reliability.
Boss Design for Robotics Assemblies
Boss geometry becomes extremely important in robotic structures.
Weak bosses may crack or loosen under repeated movement.
Reliable boss structures generally require:
- sufficient wall thickness
- balanced load distribution
- proper insert depth
- smooth stress transitions
- adequate surrounding material support
Robotics applications often require stronger bosses than static enclosures or decorative parts.
For more detailed geometry rules, see boss design for heat set inserts.
Material Selection for Robotics Inserts
Material behavior strongly affects long-term reliability.
PLA
PLA may work for low-load prototypes but often struggles under vibration and long-term cyclic loading.
Common problems include:
- creep
- cracking
- thermal softening
- loosening over time
PETG
PETG provides:
- improved flexibility
- better impact resistance
- reduced brittle cracking
It is often useful for medium-load robotic assemblies.
ABS and ASA
ABS and ASA generally provide:
- improved thermal stability
- better long-term durability
- stronger layer bonding potential
- improved vibration tolerance
These materials are commonly preferred for demanding robotics systems.
Common Failure Problems in Robotics Assemblies
Several fastening failures appear repeatedly in moving robotic systems.
Thread Loosening
Often caused by:
- vibration
- cyclic loading
- insufficient preload
- creep behavior
Insert Spinning
Usually related to:
- oversized holes
- weak boss support
- overheating
- low surrounding material volume
Layer Separation
Often caused by:
Print orientation also affects layer adhesion and insert strength, especially when robot brackets are loaded across layer lines.
- poor print orientation
- weak layer bonding
- repeated cyclic stress
Pull-Out Failure
Common causes include:
- insufficient insert depth
- low wall thickness
- repeated axial loading
- weak material support
Print Orientation and Load Direction
Print orientation strongly affects robotic fastening reliability.
Force direction should ideally align with stronger structural layer directions.
Poor orientation may increase:
- layer separation
- cracking
- pull-out failure
- torque instability
Robotics assemblies often require more careful orientation planning than simple static parts.
Serviceability in Robotics Systems
Robotics systems frequently require maintenance and modification.
Heat set inserts improve serviceability by allowing repeated assembly without damaging printed threads.
This becomes especially important for:
- actuator replacement
- electronics upgrades
- calibration adjustments
- modular system expansion
- field maintenance
Serviceable fastening systems significantly improve long-term usability.
Engineering Factors That Affect Reliability
Important related engineering factors include:
- boss wall thickness
- insert depth
- layer adhesion
- print orientation
- torque loading
- vibration exposure
- material stiffness
- thermal behavior
- screw engagement length
- surrounding material volume
Reliable fastening depends on the entire surrounding structure rather than the insert alone.
Related Failure Question
Robotics assemblies often combine repeated motion, vibration, service access, and changing load directions. For failure diagnosis, see why heat set inserts fail in robotics assemblies.
FAQ
Why are heat set inserts useful in robotics assemblies?
Robotics systems experience vibration, repeated movement, and maintenance cycles. Inserts improve fastening durability and serviceability.
Do robotic assemblies loosen over time?
Yes. Vibration and cyclic loading may gradually reduce clamp force if the surrounding structure is weak.
Is PLA suitable for robotics inserts?
PLA may work for low-load prototypes but is less reliable under vibration, heat, and long-term cyclic stress.
Why does print orientation matter in robotics parts?
Poor print orientation may weaken layer bonding and reduce structural resistance to cyclic loading.
Are inserts better than directly threaded plastic holes?
Generally yes. Inserts provide reusable metal threads with improved durability and long-term fastening stability.
Conclusion
Heat set inserts play an important role in improving fastening reliability in robotics assemblies.
Reliable robotic fastening depends on proper boss design, material selection, print orientation, insert depth, and resistance to vibration and cyclic loading.
Well-designed insert structures improve serviceability, motion stability, and long-term mechanical reliability in dynamic robotic systems.
Related Engineering Guides
- How to Choose Heat Set Inserts for 3D Printed Parts
- Heat Set Insert Hole Size Guide
- How to Design Bosses for Heat Set Inserts
- PLA vs PETG vs ABS for Threaded Inserts
- Why Heat Set Inserts Fail in 3D Printed Parts
- Pull-Out Strength of Heat Set Inserts in 3D Printed Parts
- Torque Resistance of Heat Set Inserts in 3D Printed Parts
- Layer Adhesion and Heat Set Insert Strength in 3D Printed Parts
- Heat Set Insert Installation Temperature for 3D Printed Parts
- Screw Engagement Length for Heat Set Inserts in 3D Printed Parts